3. REVIEW OF METHODS OF COMPENSATING THE EFFECT OF TEMPERATURE USING COMPENSATION CIRCUITRY IN THE ANALOG PART OF THE SIGNAL-CONDITIONING CIRCUIT
3.1. Introduction
The known circuit-compensation designs [1, 32–77] may be divided into three groups. The first group consists of designs in which the sensor for a non-electrical quantity is used at the same time as a temperature sensor. The second group is formed by designs in which, in order to sense the temperature of the sensor, components with a temperature-dependent resistance are used. In the third group of designs the temperature of the sensor is sensed by junction semiconductor devices.
Within the second and third groups we may further make a division according to the technology in which the temperature-sensitive elements are made, namely the use of discrete and of integrated components.
In the further part of this work examples of the most interesting designs will be presented.
3.2. Method using the pressure sensor as a temperature sensor
The method [61] developed at IAP PW (Institute of Industrial Automation, Warsaw University of Technology) was applied to the measurement of hydrostatic pressure, and of the temperature in the region in which that pressure acts, by means of a single sensor consisting of a semiconductor p-n junction with an arbitrary breakdown mechanism, supplied with an alternating square-wave current. The forward voltage and the reverse voltage are expressed by the following relations:
where and denote respectively the forward voltage
and the reverse voltage at the lower-range pressure and the reference temperature , and denote the pressure sensitivity of the junction in the forward and in the reverse direction respectively, while and denote respectively the temperature coefficient of the voltage in the forward and in the reverse direction respectively.1
The sign "+" or "-" of the pressure sensitivities of the junction depends on the material from which the junction is made. The sign "+" or "-" of the temperature coefficient of the reverse voltage depends on the breakdown mechanism (Zener or avalanche). The sign of the temperature coefficient of the forward voltage is always negative. The coefficients , , , are a function of the current flowing through the junction.
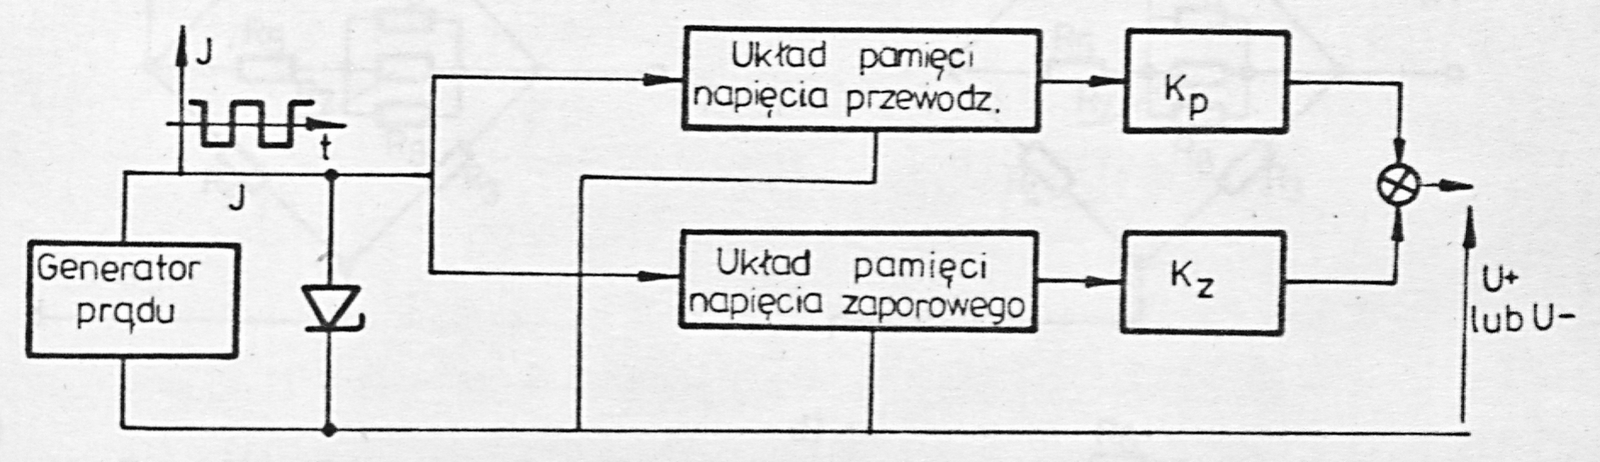
By forming, with the aid of an electronic circuit with memory (Fig. 3), the sum and the difference of the forward and reverse voltages with the appropriate proportionality coefficients , respectively, one obtains the possibility of making this sum or difference insensitive to changes of pressure or to changes of temperature
and
In the case where , , , are not a function of temperature and pressure, two of the four relations above can be satisfied, and one obtains a pressure-compensated temperature transducer or a temperature-compensated pressure transducer.
Labels: Układ pamięci napięcia przewodz. = forward-voltage memory circuit; Generator prądu = current generator; Układ pamięci napięcia zaporowego = reverse-voltage memory circuit; lub = or
3.3. Method using discrete variable-resistance components to sense temperature
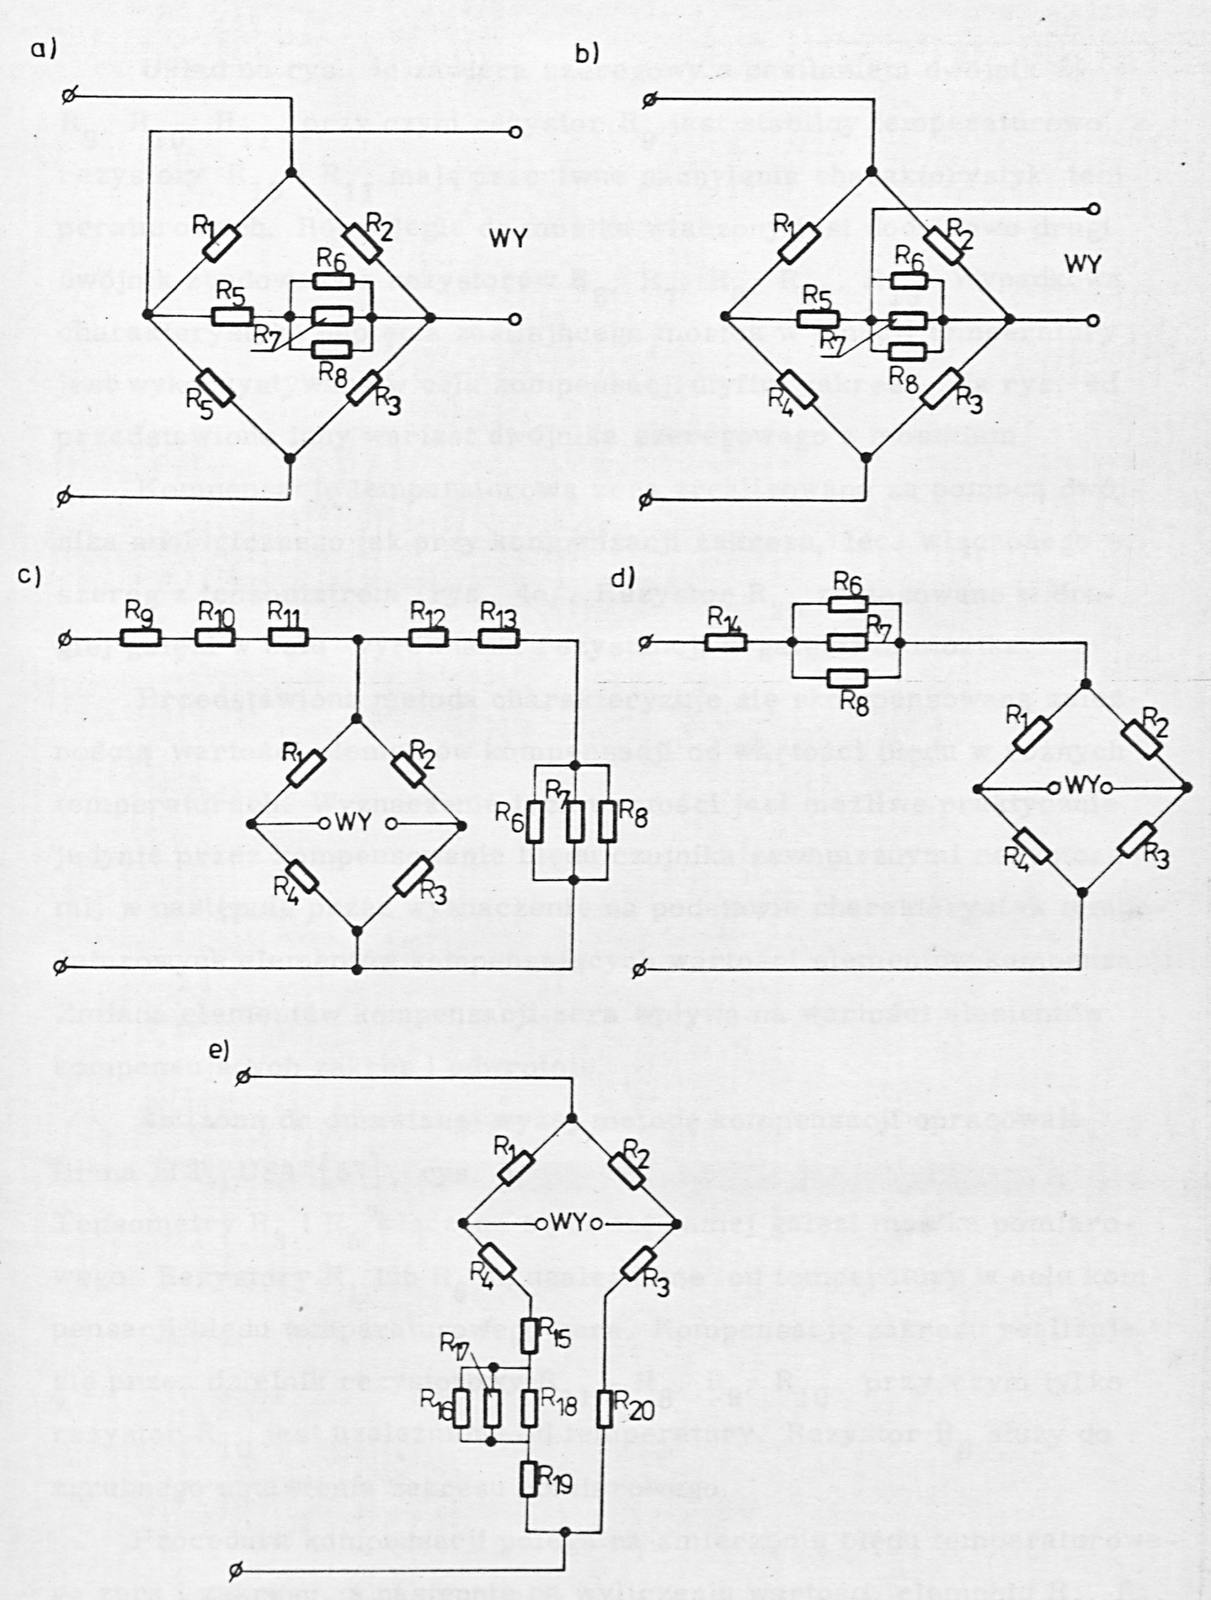
The compensation method presented in [71], proposed by Statham (USA), consists in connecting two-terminal networks with a temperature-dependent resistance in series with the arms of the strain-gauge bridge, or in parallel with them, in order to compensate the zero drift, and in connecting analogous two-terminal networks in series with the bridge, or in series-parallel with it, in order to compensate the span.
Figs. 4a, 4b, 4c and 4d show variants of the temperature compensation of the span. The resistances of the strain gauges are denoted by to . The compensating two-terminal network in Fig. 4a is built from the resistive components to , where the resistor is temperature-compensated, the resistance value of the component increases as a function of temperature, while that of the component decreases. The compensation consists in a variable loading of the bridge output. The circuit in Fig. 4b was modified by introducing a stronger division of the output signal by means of the resistor .
Labels: WY = output (wyjście)2
The circuit in Fig. 4c contains, in series with the supply, the two-terminal network , , , where the resistor is temperature-stable and the resistors and have temperature characteristics of opposite slopes. In parallel with the bridge a second two-terminal network, built from the resistors , , , , , is additionally connected. The resultant characteristic of the bridge excitation voltage as a function of temperature is used to compensate the span drift. Fig. 4d shows another variant of the two-terminal network in series with the bridge.
The temperature compensation of the zero was realized by means of a two-terminal network analogous to that used for the span compensation, but connected in series with a strain gauge (Fig. 4e). The resistor was used in the second arm in order to equalize the resistances in the arms of the bridge.
The method presented is characterized by a complicated dependence of the values of the compensation components on the values of the error at the various temperatures. Determining these values is in practice possible only by compensating the sensor error with external resistors, and then by determining the values of the compensation components on the basis of the temperature characteristics of the compensating components. A change of the zero-compensation components affects the values of the components compensating the span, and vice versa.3
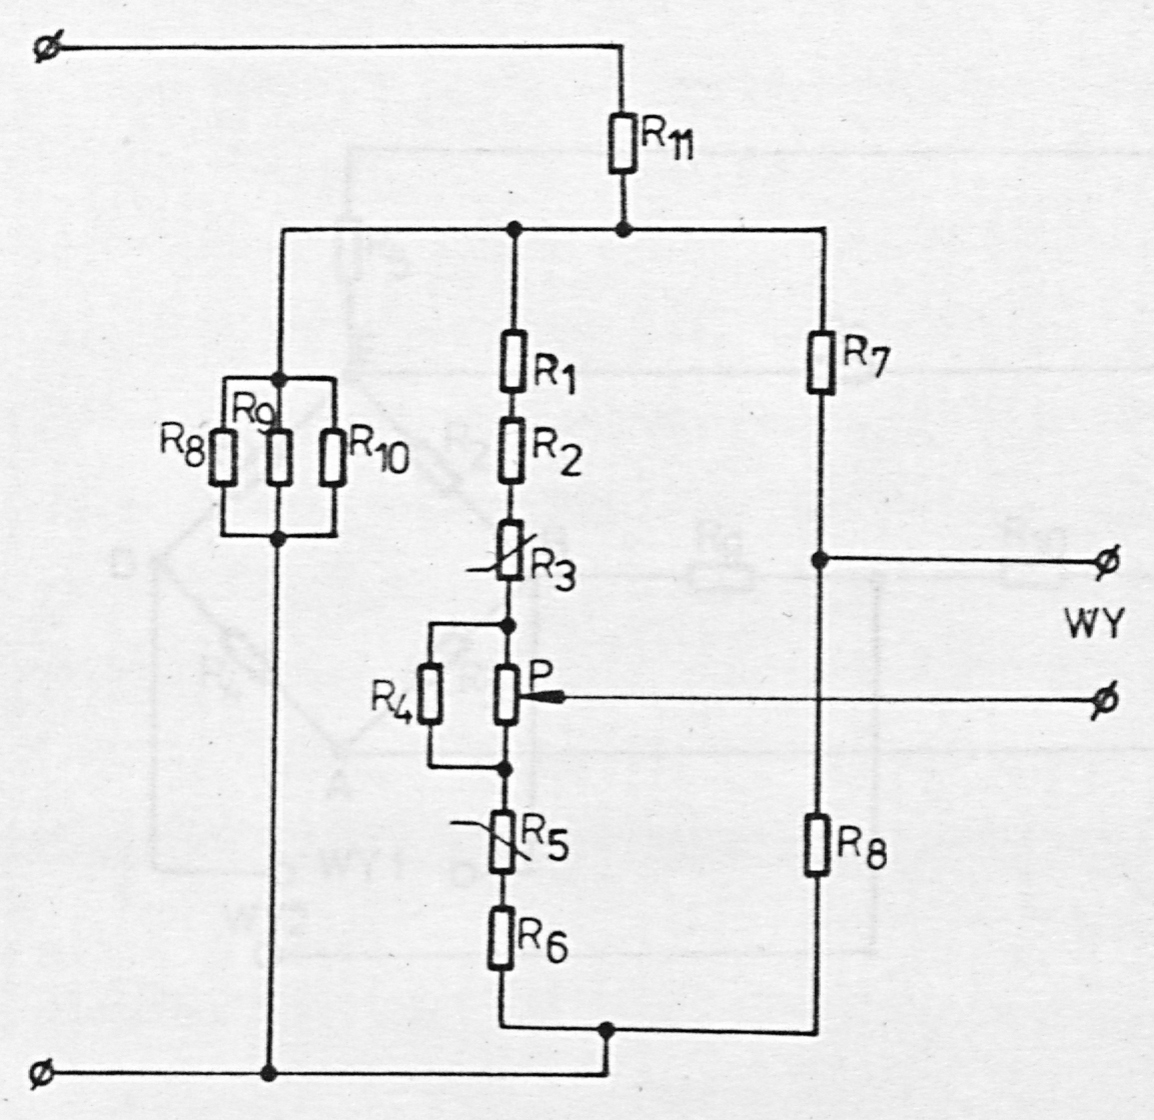
A compensation method close to the one discussed above was developed by ITT (USA) [57], Fig. 5. The strain gauges and are connected in the same arm of the measuring bridge. The resistors or are made temperature-dependent in order to compensate the temperature error of the zero. The span compensation is realized by the resistive divider - , , , where only the resistor is temperature-dependent. The resistor serves for the coarse span setting.
The compensation procedure consists in measuring the temperature error of the zero and of the span, and then in calculating the values of the components , , , , which coarsely calibrate the value of the signal at the beginning and at the end of the measuring range at the reference temperature and ensure two-point temperature compensation.
Labels: WY = output (wyjście)
The main drawback of the method is the complicated dependence of the values of the compensating components on the values of the errors.
Another design of the compensation method was introduced by Kulite (USA) [77], Fig. 6.
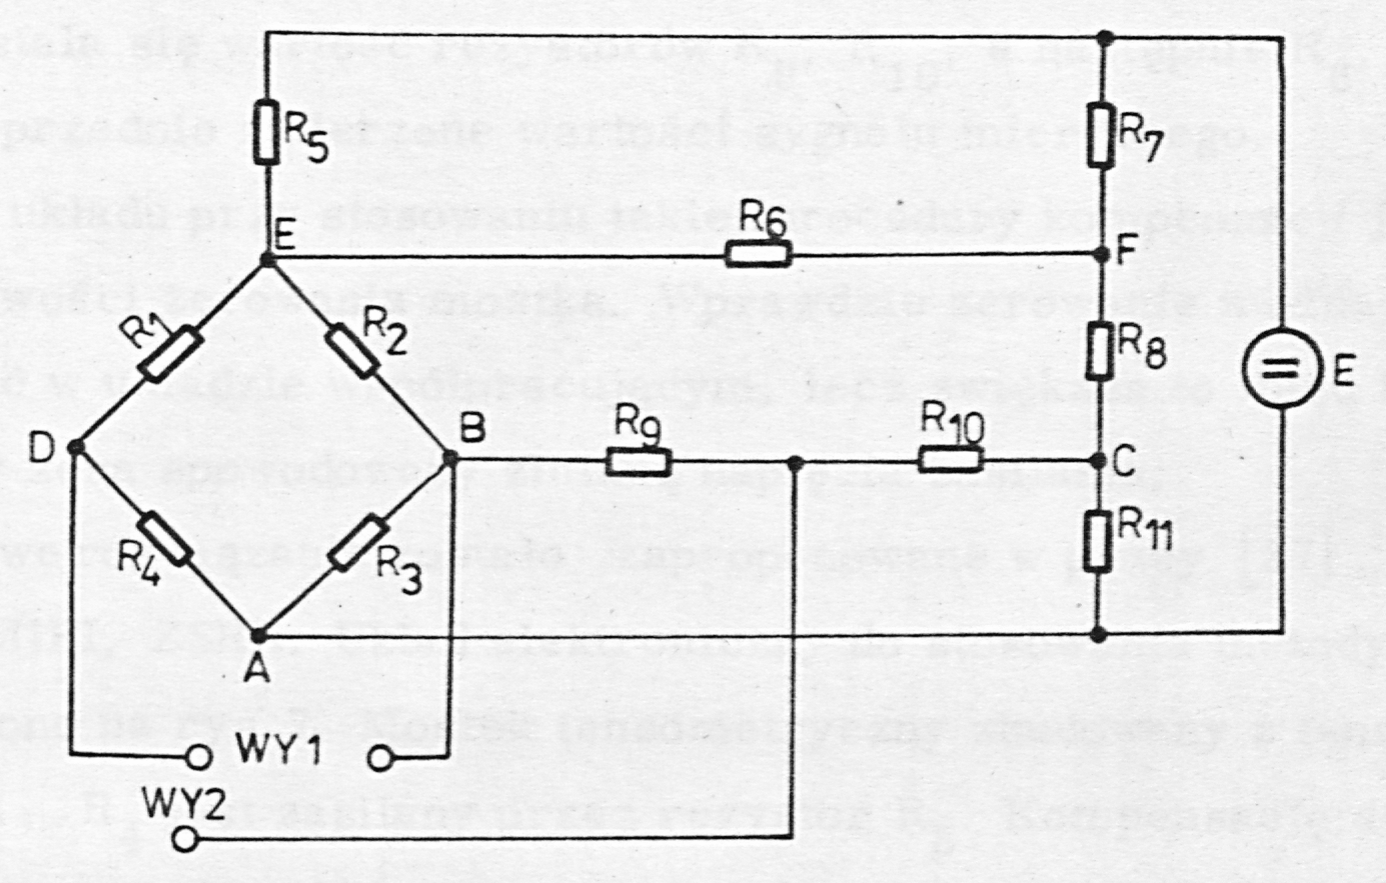
In order to temperature-compensate the zero of the strain-gauge bridge built from the strain gauges to , the voltage between the points A and C is equalized at the reference temperature with the voltage between the points A and B. Under these conditions the current flowing through the resistors and is equal to zero and the value of these resistances does not affect the voltage across the diagonal DB of the strain-gauge bridge. By making the voltage between the points A and C temperature-dependent by means of the resistors , , , , one obtains the possibility of producing, across the diagonal of the strain-gauge bridge, a change of voltage which compensates the zero drift. The value of the required current flowing through the resistors and depends on the value of their resistance and does not change the balance condition of the strain-gauge bridge at the reference temperature.
Labels: WY1 = output 1; WY2 = output 2
Two outputs of the circuit are proposed. The output is connected directly across the diagonal DB of the strain-gauge bridge, while the output additionally contains the divider -, which modifies the course of the compensating signal.4
The span compensation was obtained by changing the bridge excitation voltage. If at the reference temperature the voltage between the points A and E is equal to the voltage between the points A and F, then the value of the resistance does not affect the values of these voltages. If at another temperature these voltages differ, a current flows through , and by selecting the temperature characteristic of the voltage AF by means of the resistors , , and the characteristic of the resistor one obtains the possibility of compensating the span, i.e. of the required increase or decrease of the voltage AE across the bridge.
The advantage of the circuit is the possibility of using a simple compensation procedure. At the reference temperature the voltages are equalized
and the value of the voltage at the output of the circuit is measured at the lower and at the upper value of the range of the measured pressure. At the compensation temperature the values of the resistors , , and then , are set so as to obtain the previously measured values of the measured signal.
The drawback of the circuit, when such a compensation procedure is used, is the lack of any possibility of nulling the bridge. Admittedly the nulling can be realized in an associated circuit, but this increases the temperature error of the zero caused by the change of the supply voltage.
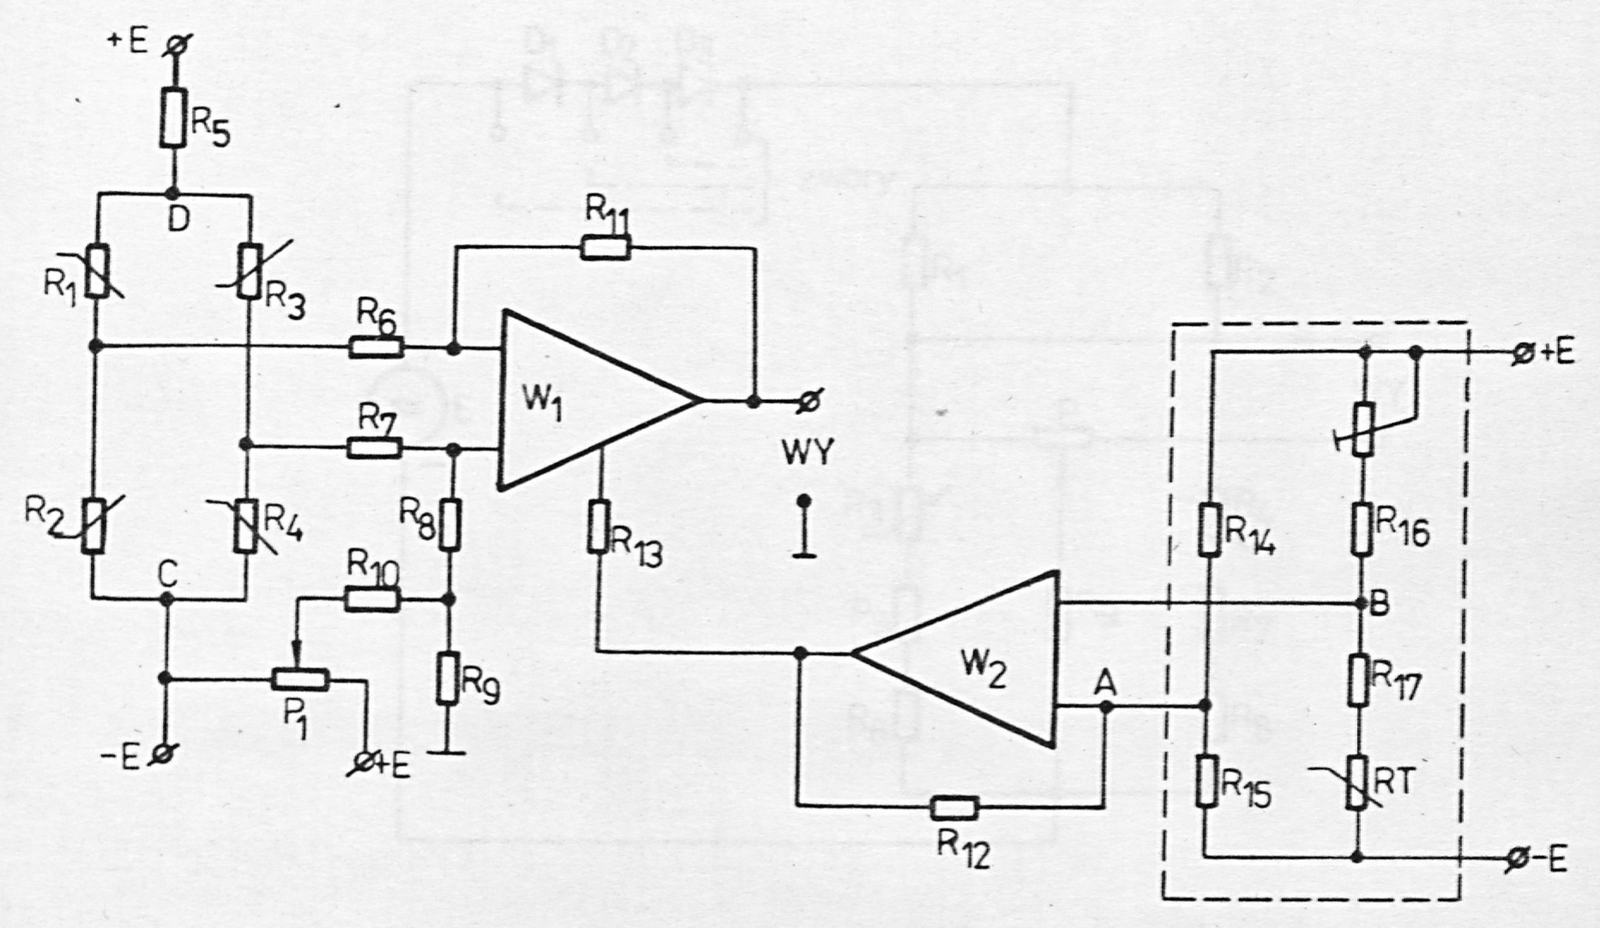
An interesting design was proposed in [37], developed at MIFI (Moscow Engineering Physics Institute), USSR. The electronic circuit for applying the method is shown in Fig. 7. The strain-gauge bridge built from the strain gauges to is supplied through the resistor . The compensation of the zero drift is carried out by means of the auxiliary bridge M containing the thermistor RT. At the reference temperature the voltage across the diagonal AB of the bridge is equal to zero (which is obtained by means of the potentiometer P2), and the zero adjustment of the transducer is performed with the potentiometer P1. At the compensation temperature the output signal of the amplifier W1 is brought back to its previous value by adding to the sensor signal the output signal of the amplifier W2 with a weighting factor set by the resistor or . The output signal of the amplifier W2 is made temperature-dependent by means of the auxiliary bridge M.
The span compensation is realized by means of the resistor and by making use of the variable resistance of the strain gauges to as a function of temperature, which causes changes of the voltage across the bridge.
The method allows a relatively simple two-point compensation of the zero drift and a coarse compensation of the span. It requires, however, the use of an additional operational amplifier, which is its drawback.
Labels: WY = output (wyjście)
3.4. Methods using discrete junction semiconductor devices as temperature sensors.
The designs presented below make use of the linear dependence on temperature of the forward voltage of a diode or of the base-emitter voltage of a transistor. At the same time, variable-resistance components may be used for the compensation.
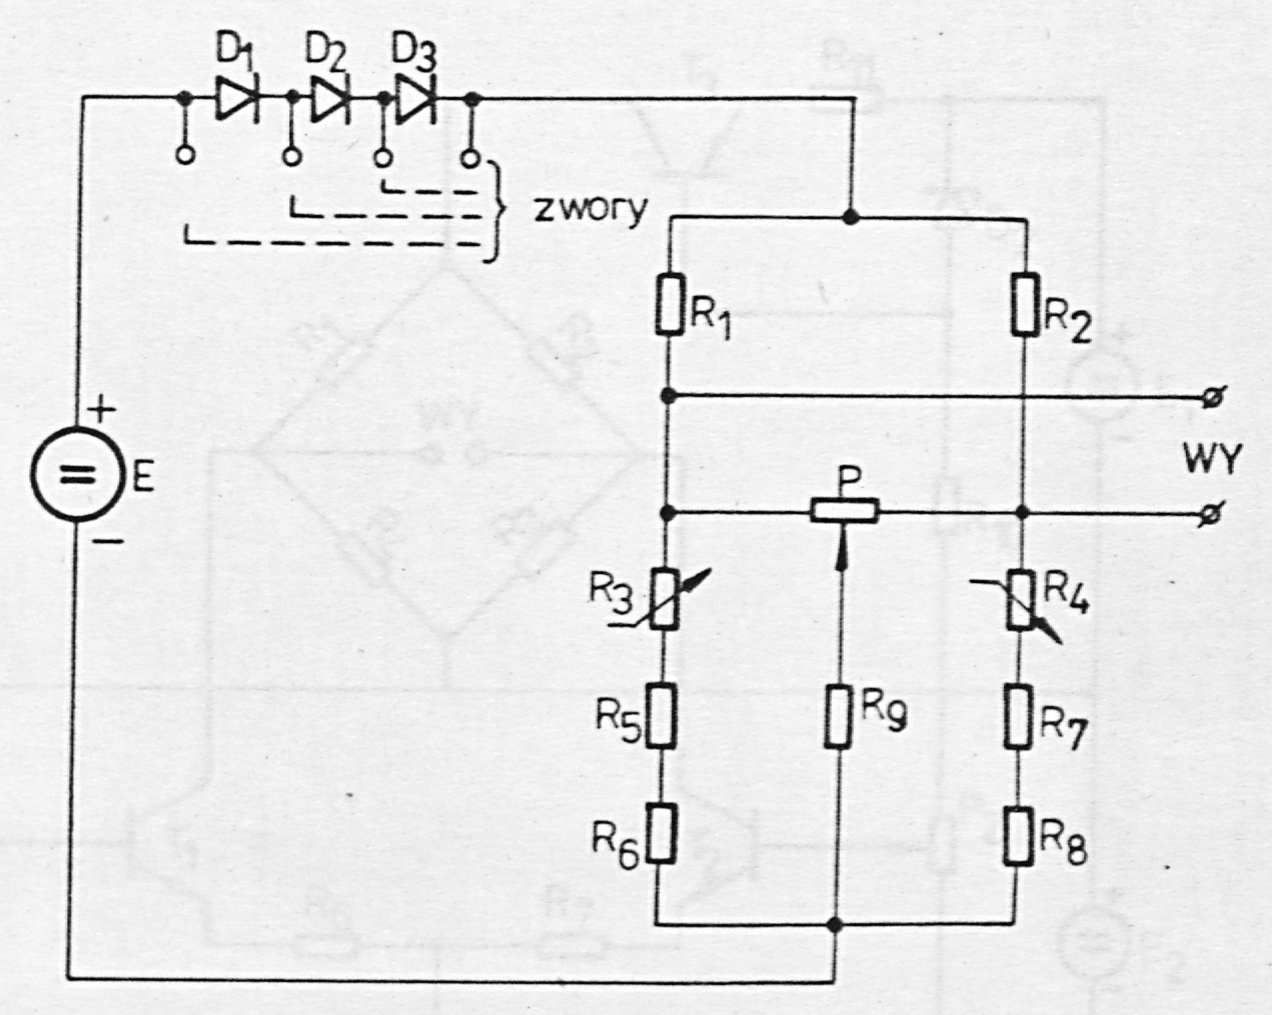
In the method used at Mera-Pnefal (Poland) [33], the compensation of the zero drift is realized by means of resistive components (Fig. 8). In the measuring bridge two strain gauges and are placed in opposite arms. The values of the resistors and are made independent of temperature, while the values of the resistors and have a positive temperature coefficient of resistance. By measuring the total resistance and required for nulling the bridge at two temperatures one obtains the information necessary to calculate the resistors to , where one of the resistors , is always equal to zero. The potentiometer P serves for the precise nulling of the bridge.
Labels: zwory = jumpers; WY = output (wyjście)
The span compensation is obtained, similarly to the designs of Bell & Howell (USA) [60], by means of diodes connected in series with the bridge. The voltage across the diodes decreases with increasing temperature, which causes an increase of the voltage across the measuring bridge, which compensates the decrease of the pressure sensitivity. The number of diodes must be calculated on the basis of a measurement of the value of the span drift with temperature.
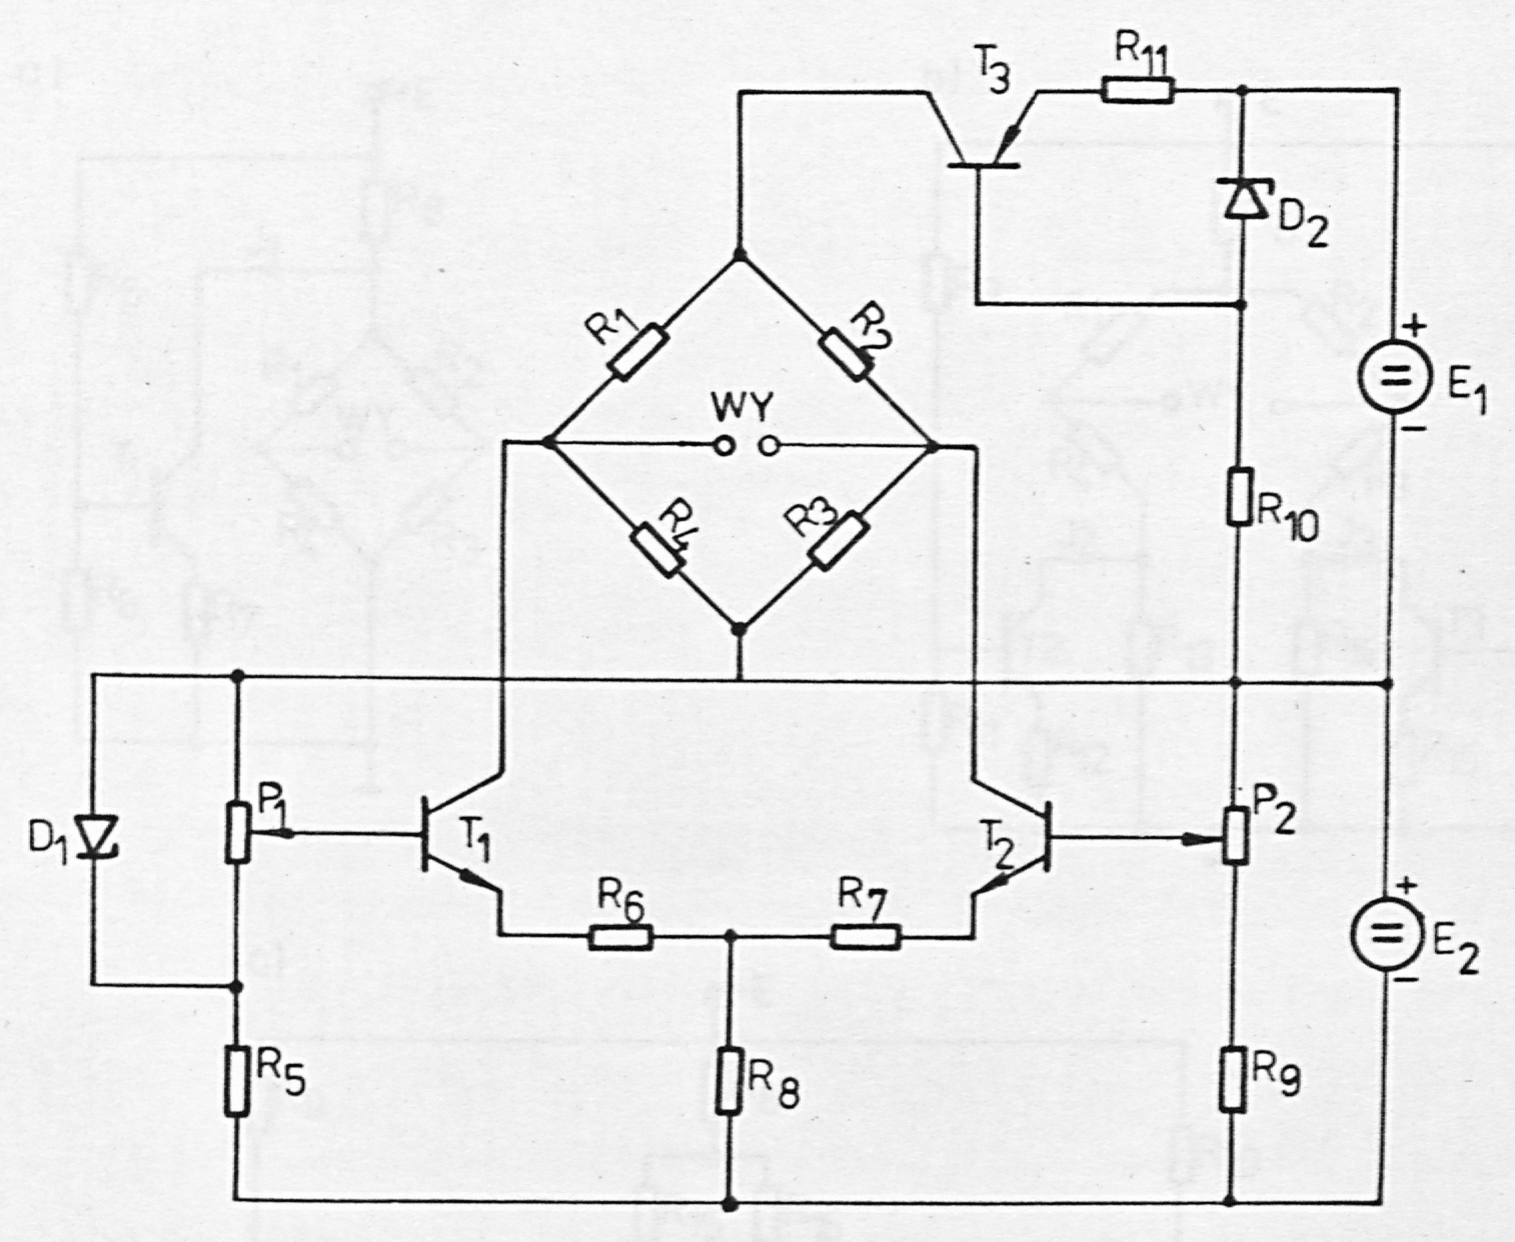
The compensation method [72] developed by Honeywell (USA) uses the diode D1 (Fig. 9) as the temperature-sensing element. The balance of the measuring bridge built from the strain gauges , , , depends on the values of the currents produced by the current sources built on the transistors T1 and T2. The mean value of these currents can compensate the span drift with temperature by changing the resultant voltage across the bridge. In order to compensate the zero drift of the sensor, the value of the necessary change of the difference of the currents of the two sources is changed first with the potentiometer P1, and then the bridge is nulled with the potentiometer P2.
Labels: WY = output (wyjście)
The compensation of the span drift with temperature can also be obtained by making the current produced by the transistor T3 temperature-dependent, by selecting the temperature coefficient of the diode D2 or by using a temperature-dependent resistor .
The settings of the potentiometers P1 and P2 which ensure temperature compensation are mutually dependent in this circuit.
An interesting temperature-compensation design [32, 73] was proposed by Bell & Howell (USA). The method uses the base-emitter junctions of transistors as temperature sensors.
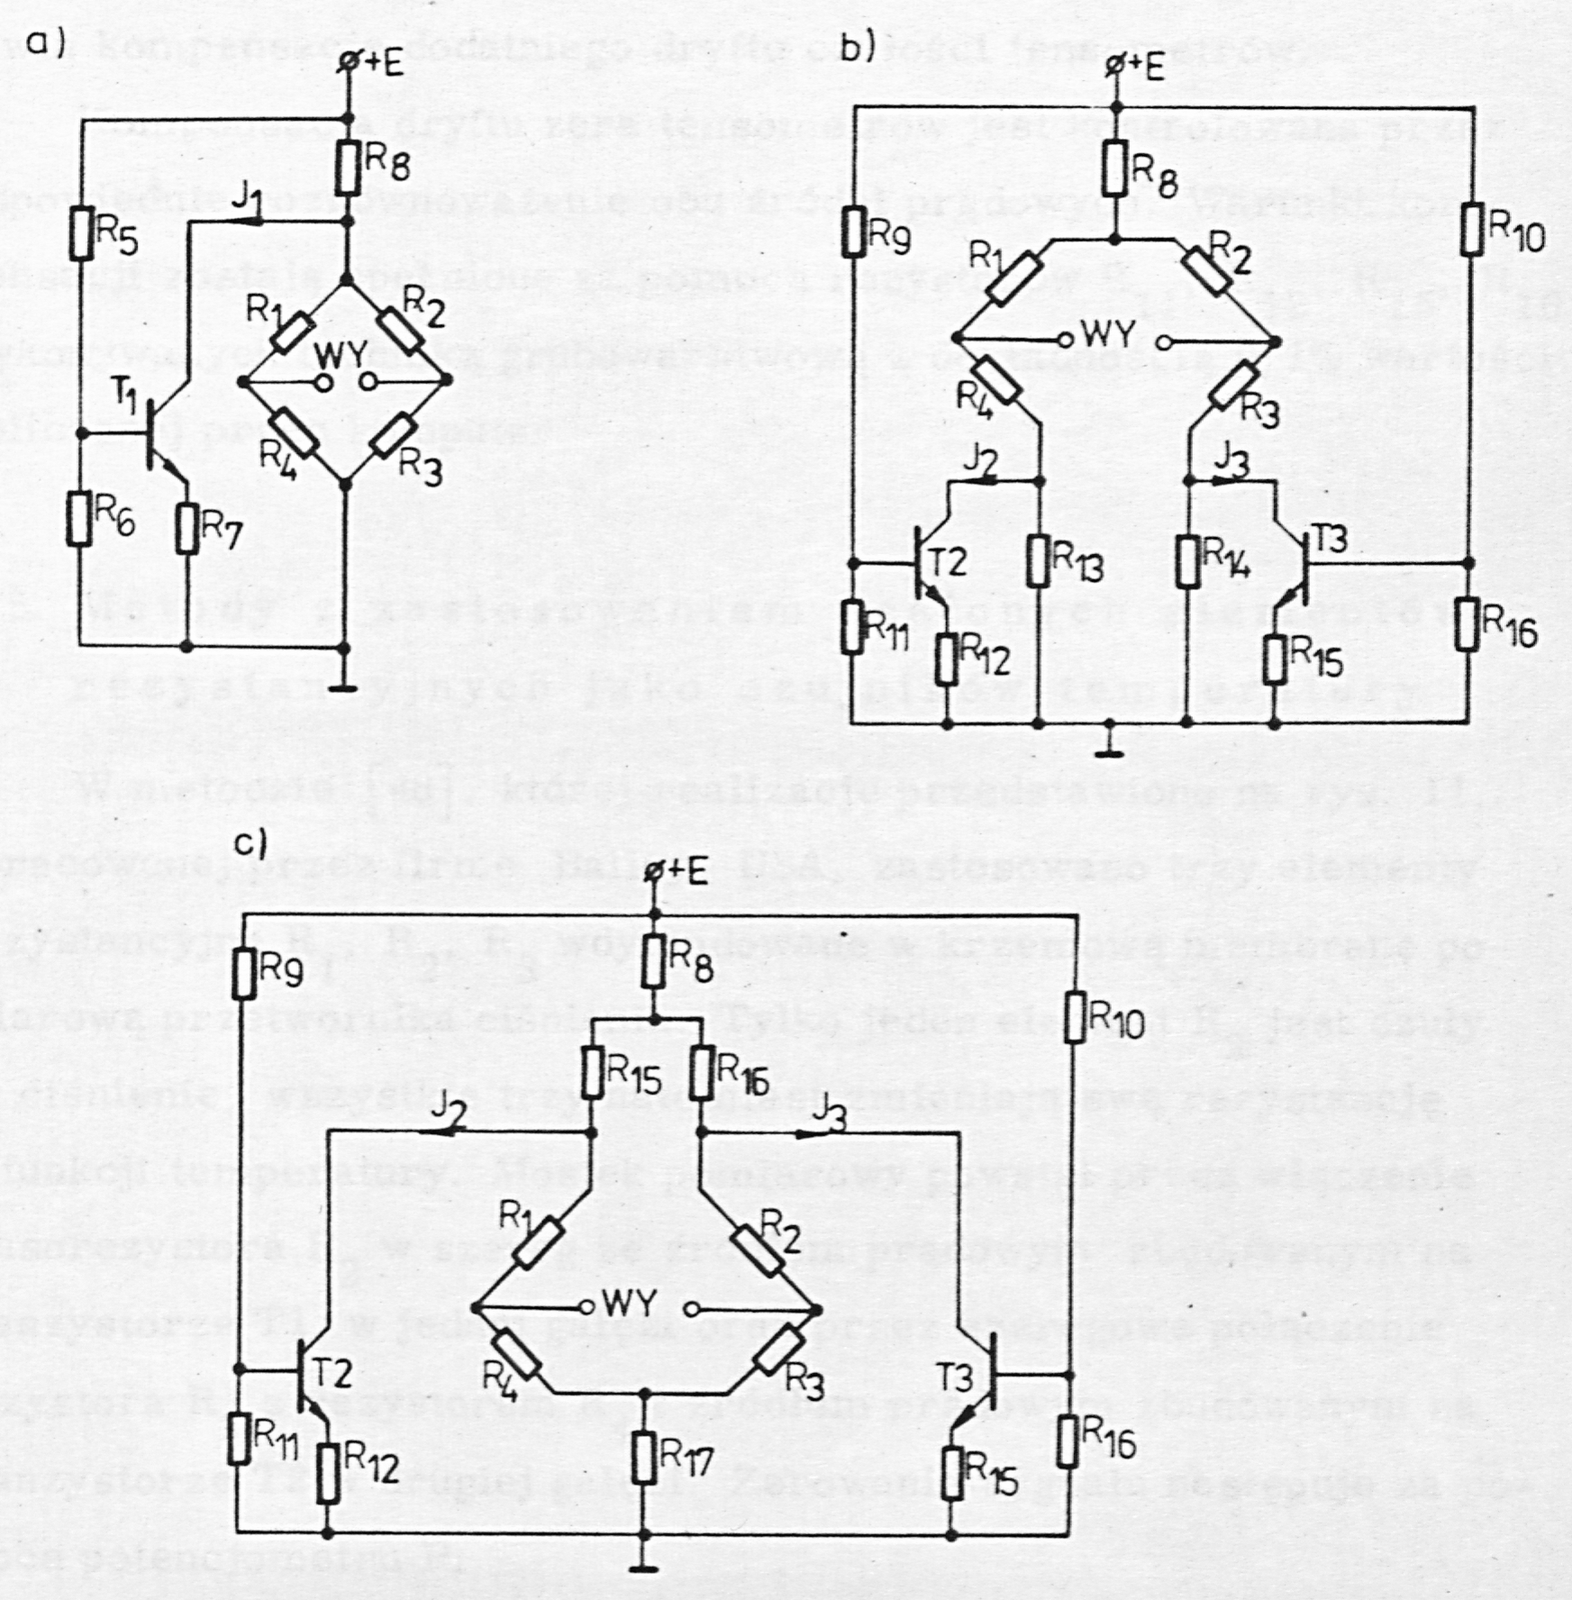
The compensation of the span drift is shown in Fig. 10a. As a result of the decrease of the base-emitter voltage of the transistor T1 with increasing temperature, the current increases, causing a decrease of the voltage across the measuring bridge containing the strain gauges to .
Labels: WY = output (wyjście)5
Figs. 10b and 10c show the circuit proposed for the simultaneous compensation of the span and of the zero. A simultaneous increase of the currents and delivered by the current sources built on the transistors T2 and T3 causes:
- in the circuit of Fig. 10b: an increase of the voltage across the measuring bridge, which makes it possible to compensate a negative sensitivity drift of the strain gauges,
- in the circuit of Fig. 10c: a decrease of the voltage across the bridge, which makes it possible to compensate a positive sensitivity drift of the strain gauges.
The compensation of the zero drift of the strain gauges is controlled by an appropriate unbalance of the two current sources. The compensation conditions are satisfied by means of the resistors , , , , made in thick-film technology to an accuracy of 0.1 % of the value calculated by a computer.
3.5. Methods using integrated resistive components as temperature sensors
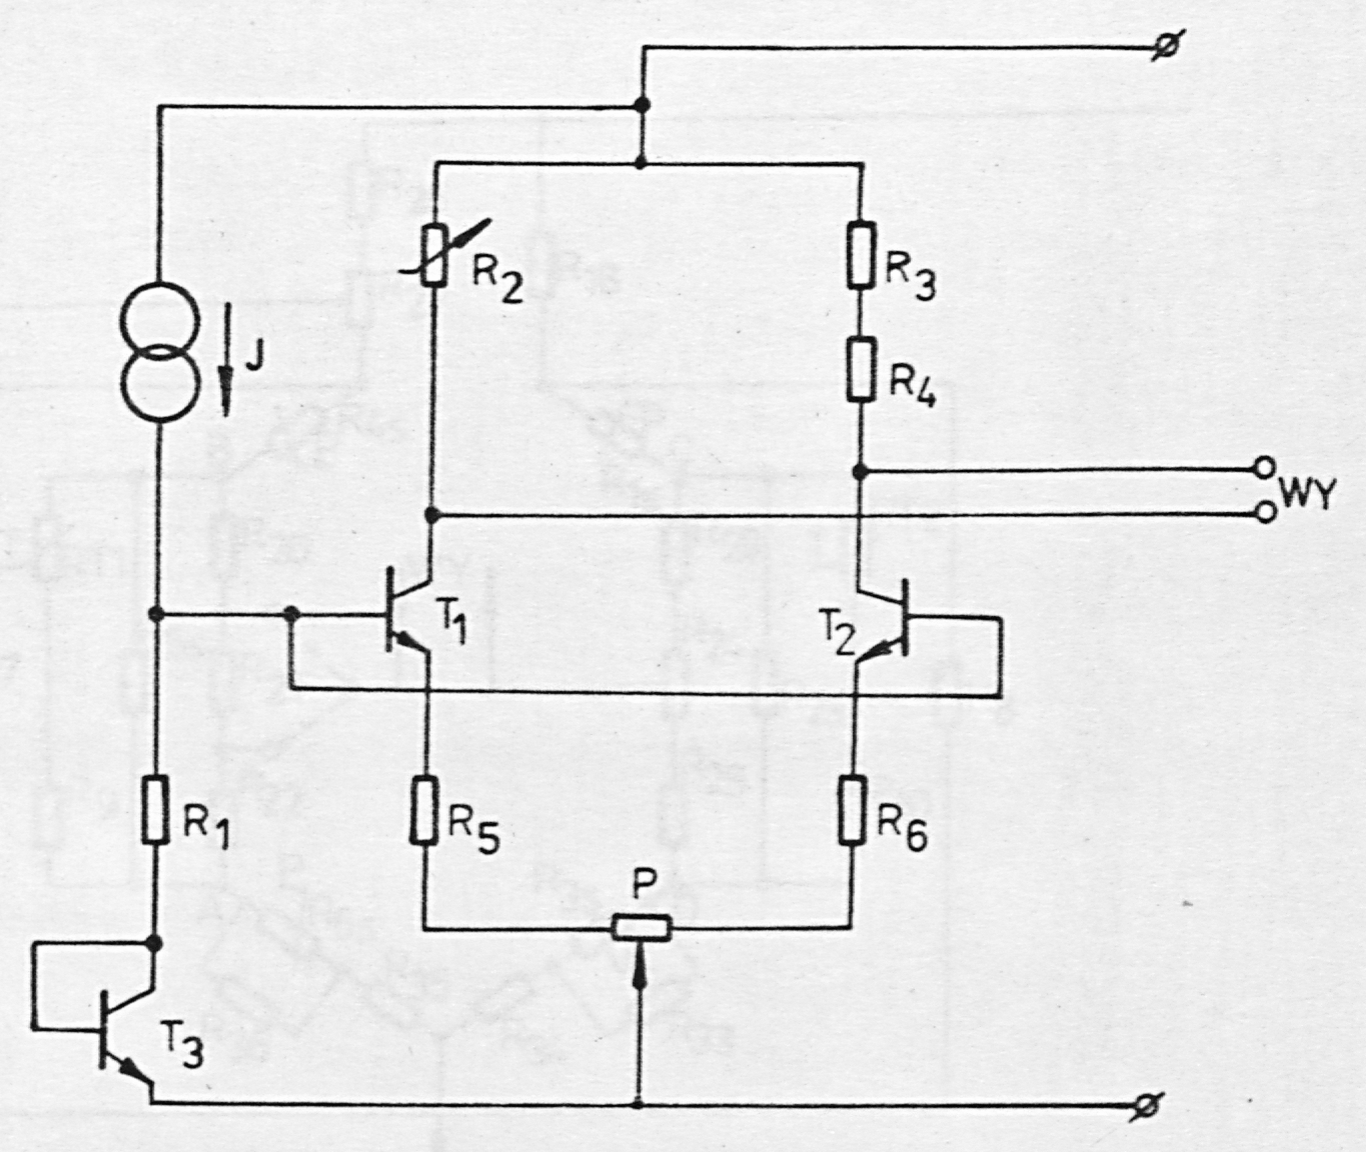
In the method [48], whose realization is shown in Fig. 11, developed by Bailey (USA), three resistive components , , , diffused into the silicon sensing diaphragm of the pressure transducer, are used. Only one component, , is sensitive to pressure, whereas all three change their resistance as a function of temperature. The measuring bridge was formed by connecting the piezoresistor in series with the current source built on the transistor T1 in one arm, and by the series connection of the resistor with the resistor and the current source built on the transistor T2 in the other arm. The signal is zeroed by means of the potentiometer P.6
The temperature compensation of the zero drift was accomplished by selecting an appropriate value of the temperature-stable resistor , which sets the resultant temperature coefficient of the voltage in the right-hand arm of the bridge equal to the temperature coefficient of the voltage across the strain gauge. Since in the bridge it is the absolute voltage increments that compensate one another, the voltage increments in the two arms also depend on the ratio of the currents produced by the transistors T1 and T2. This makes it possible to compensate the zero drift of the transducer both when the strain gauge changes more strongly as a function of temperature than the resistor , and in the opposite case.
The compensation of the span drift with temperature was obtained as a result of making temperature-dependent the voltage controlling the source current of the
Labels: WY = output (wyjście)
current sources on the transistors T1, T2. This dependence was obtained by making use of the diffused resistor , supplied by the temperature-stable current source I, to produce the said control voltage. The diode-connected transistor T3 compensates the temperature changes of the base-emitter voltages of the transistors T1 and T2.
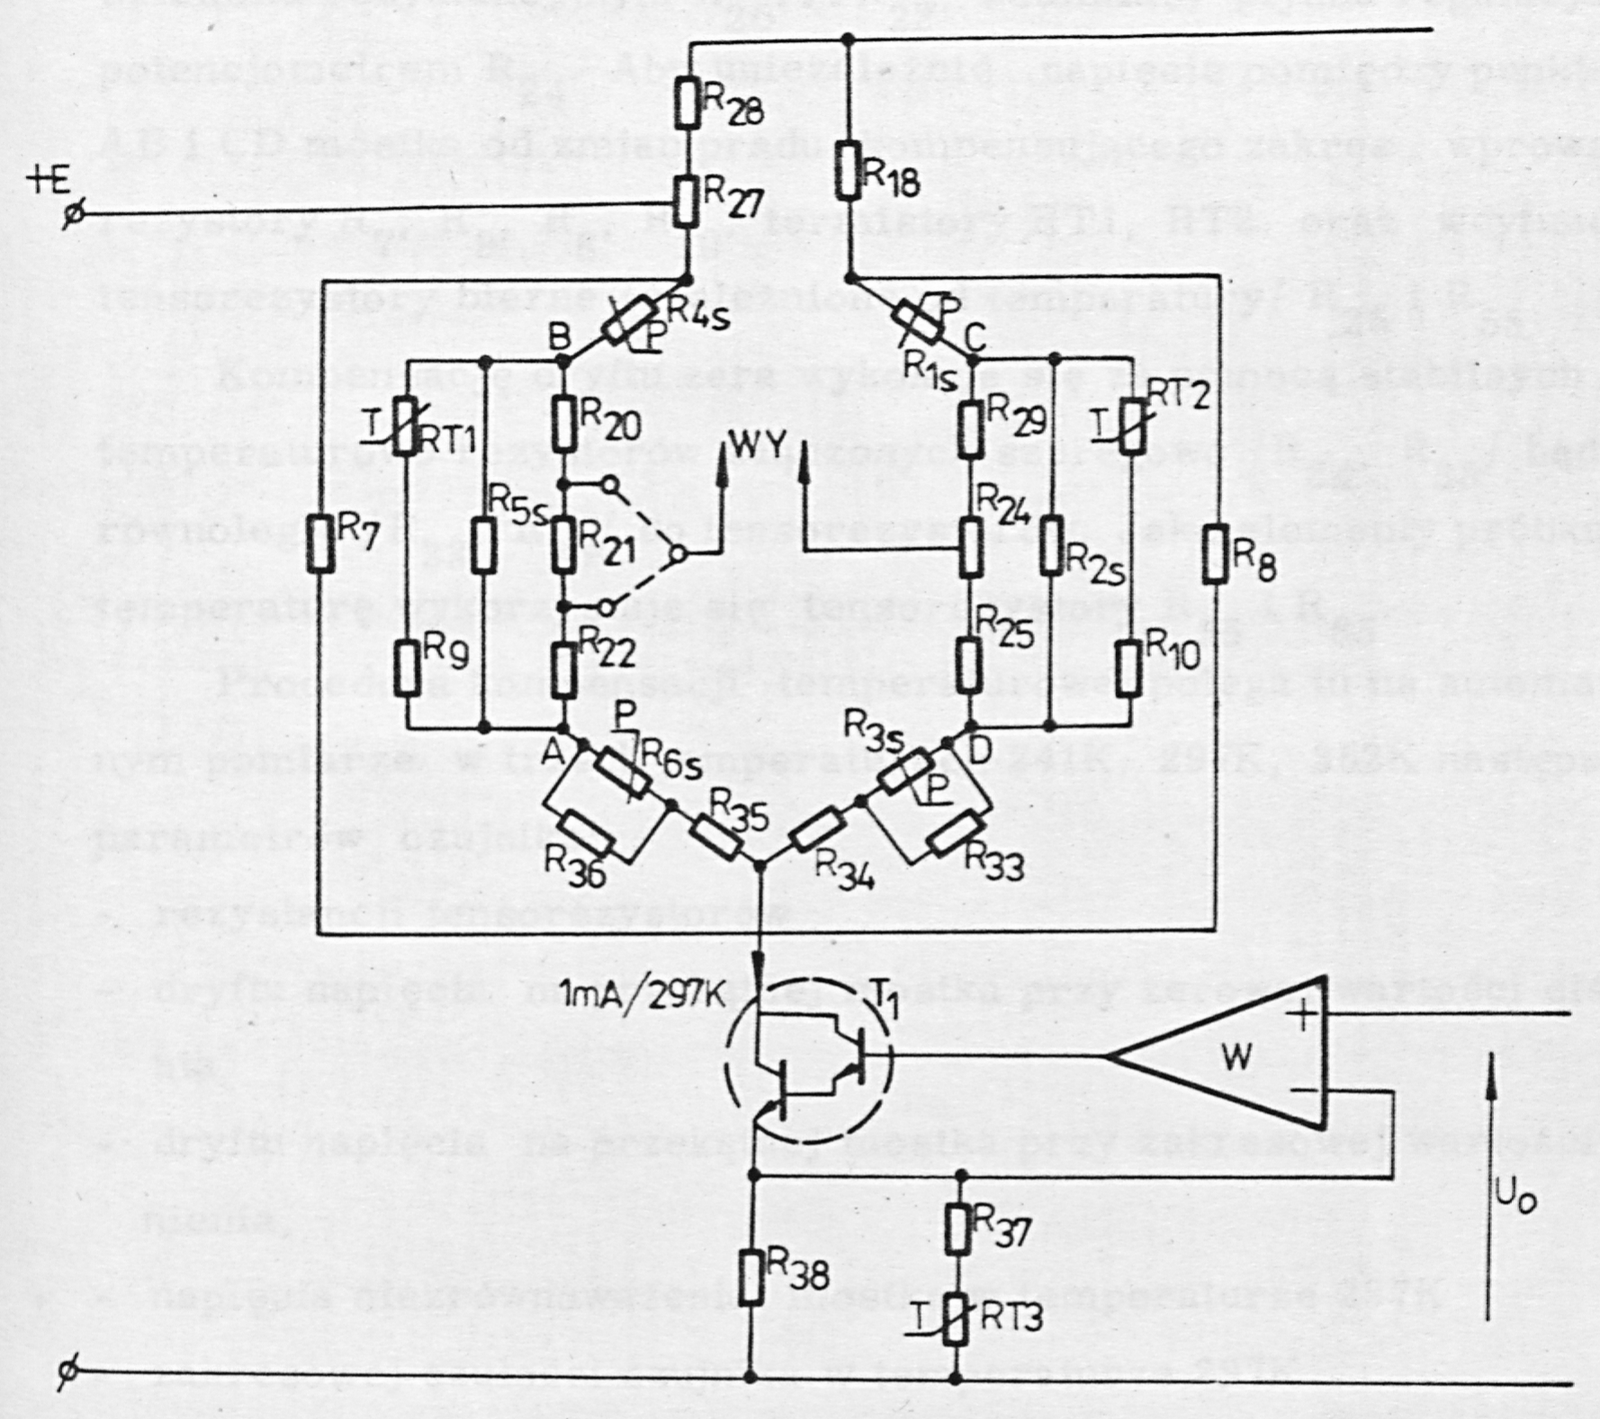
A very elaborate temperature-compensation method [33, 39, 40] was developed by Honeywell (USA) for a family of industrial transducers of pressure and derived quantities based on an integrated silicon piezoresistive sensor made in planar technology. The compensation circuit is shown in Fig. 12. It performs the following functions:
- it compensates the temperature error of the zero
- it compensates the temperature error of the span
- it compensates the zero-suppression voltage, which shifts the starting point of the transfer characteristic within the region of ±100 % of the measuring range.
Labels: WY = output (wyjście); W = amplifier (wzmacniacz)
The sensor is built from six resistors to diffused into the silicon sensing diaphragm. Two of these resistors, and , decrease their resistance with increasing pressure, the next two, and , increase it, and the remaining two, and , are not sensitive to pressure.7
The temperature compensation of the span is realized by making temperature-dependent the current produced by the current source built on the Darlington pair T1 and the amplifier W. The dependence is obtained by means of a two-terminal network built from the thermistor
RT3 and the resistors and .
The stepped zero offset is obtained by means of the voltage across the resistive divider to , while the continuous zero adjustment is by the potentiometer . In order to make the voltage between the points AB and CD of the bridge independent of changes of the span-compensating current, the resistors , , , and the thermistors RT1, RT2 were introduced, and the passive (pressure-insensitive, temperature-dependent) piezoresistors and were diffused in.8
The compensation of the zero drift is performed by means of temperature-stable resistors connected in series (, ) or in parallel (, ) with the piezoresistors. The piezoresistors and are used as the temperature-sensing elements.
The temperature-compensation procedure here consists in the automatic measurement, at three temperatures 241 K, 297 K, 352 K, of the following parameters of the sensor:
- the resistance of the piezoresistors
- the drift of the voltage across the bridge diagonal at zero pressure
- the drift of the voltage across the bridge diagonal at the full-scale pressure,
- the bridge unbalance voltage at the temperature 297 K
- the full-scale sensitivity of the sensor at the temperature 297 K
- the temperature hysteresis
- the pressure hysteresis.
On the basis of the measured parameters of the sensor a computer calculates the values of the compensation components. The values of the components compensating the span drift and the drift of the zero-suppression voltage are coupled with one another. Depending on the parameters of the sensor, one of three sets of values of these components is used, which suffices to keep the errors of the transducer at the level of 0.07 %/10 K.
The total number of possible values of the resistors to compensating the span drift which may occur in practice is 110, these values being quantized so as to obtain a resultant zero drift at the level of 0.07 %/10 K.
The method presented has a fundamental drawback: it requires stocking a large number of components, of which only an insignificant percentage will be used in the production process.
The advantage of designs using integrated temperature-sensing elements is the smaller temperature gradients between these elements and the sensor, resulting from the small thermal resistance between these elements.
3.6. Method using integrated semiconductor devices as temperature sensors
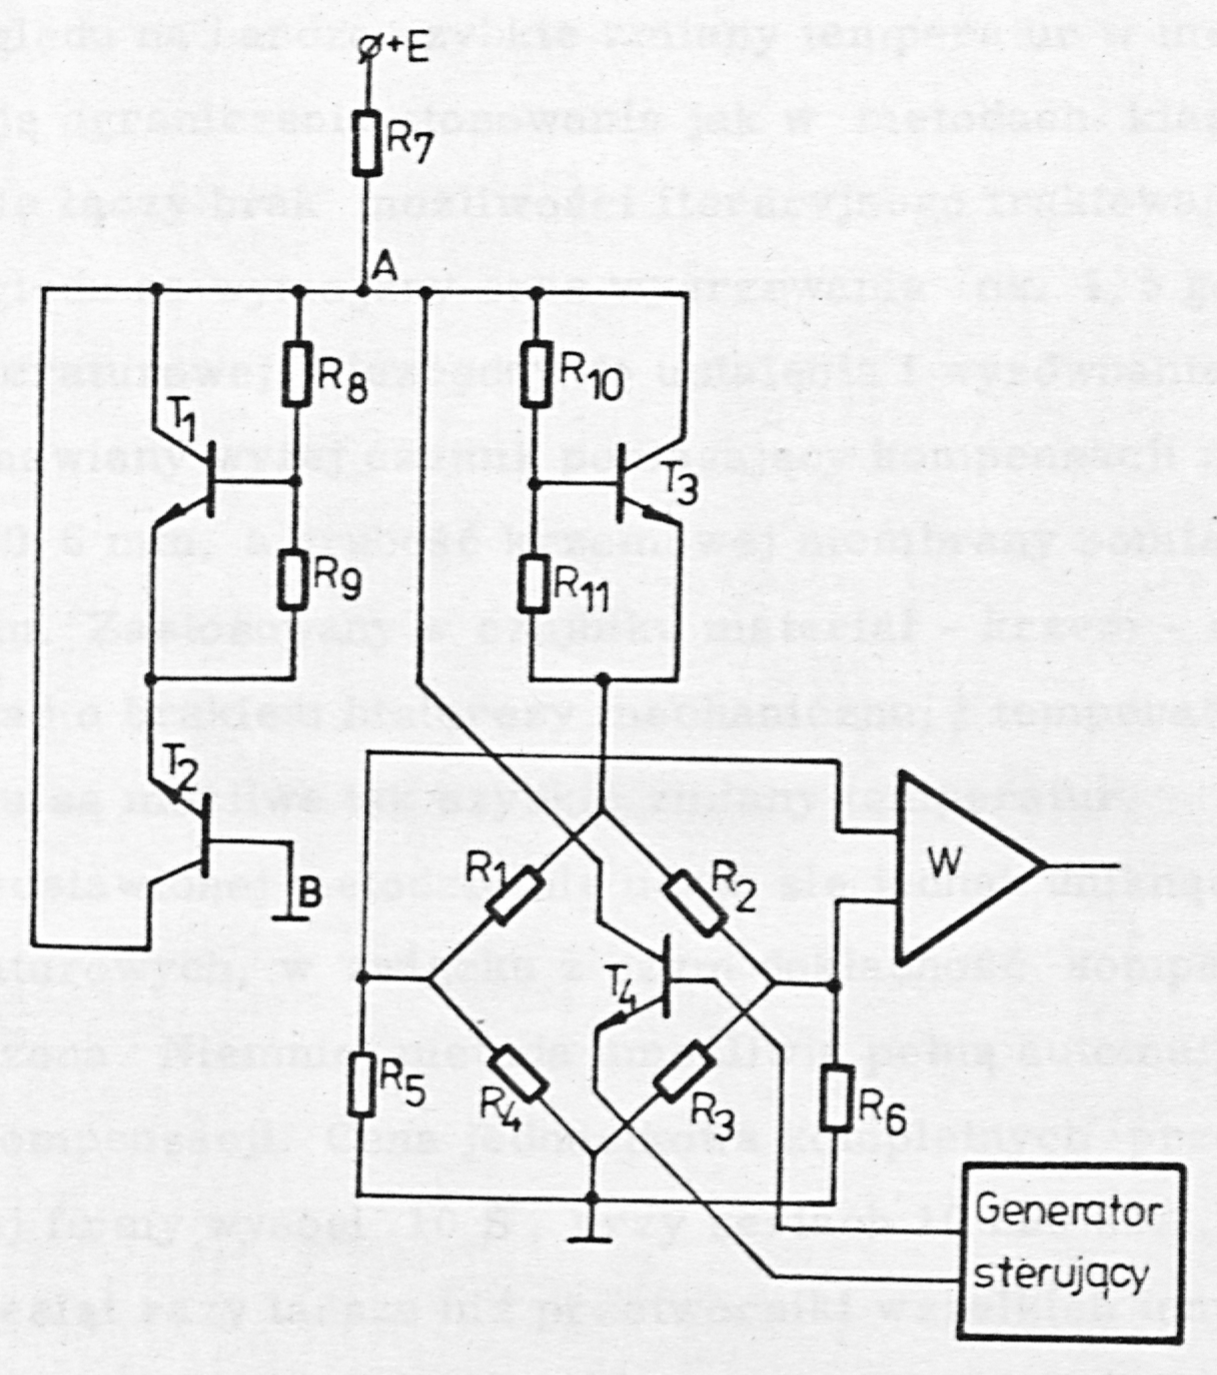
The conceptually most interesting compensation method was developed by National Semiconductor (USA) [1, 42, 70]. This method is closely tied to the integrated pressure sensor also developed at that company. This sensor is built from four strain gauges , , , (Fig. 13) diffused into the silicon sensing diaphragm. Between these strain gauges the transistor T4 is diffused. Into the same silicon chip, outside the region of the diaphragm, the transistors T1, T2, T3 and the operational amplifier W are also diffused. All the diffused components are located close to one another, owing to which the thermal resistance between them is very small.9
The transistor T4 is used as a heater controlled by a square wave from a drive generator. The rise time of the temperature from 298 K to 423 K of all the diffused components, with the exception of the amplifier W, is about 200 ms (thermal time constant approx. 100 ms, thermal resistance approx. 300 K/W). As a result it becomes possible to change the temperature of the diffused components at a frequency of the order of a few Hz.
The first element subjected to temperature compensation in the sensor circuit is the supply voltage between the points A and B. This voltage is supplied by a Zener diode formed by the reverse-biased base-emitter junction of the transistor T2, with a voltage of approx. 6.4 V and a temperature coefficient of approx. +2.5 mV/K. The temperature compensation is obtained by means of the so-called "" circuit (a multiplier) - a voltage
Labels: W = operational amplifier (wzmacniacz); Generator sterujący = drive generator
source with a voltage equal to "n" times the base-emitter voltage of the transistor T1. By changing the temperature of the components periodically, the changes of the supply voltage are observed, and in an automatic computer-controlled cycle the value of the thick-film resistor is corrected with a laser trimmer until these changes are equal to zero.
After applying the lower-range pressure, the change of the voltage across the diagonal of the strain-gauge bridge resulting from the changes of temperature is brought to zero in the manner given above, by changing the values of the thick-film resistors .
After the lower range value has been compensated, the full-scale pressure is applied and, again observing the changes of the voltage across the diagonal of the strain-gauge bridge, they are brought to zero by means of the second
"n·" circuit on the transistor T3 and the resistors , .
Owing to the very rapid changes of temperature, this method is free of the limitations of application found in the classical methods, which are bound up with the impossibility of treating the compensation iteratively because of the required thermal soak time (approx. 1.5 h) in the temperature chamber, necessary for the temperatures to settle and equalize. The sensor discussed above which is subjected to compensation has the dimensions 2.9 × 4.2 × 0.6 mm, and the thickness of the silicon sensing diaphragm is 25 µm. The material used in the sensor - silicon - is moreover characterized by the absence of mechanical and temperature hysteresis, owing to which such rapid changes of temperature are possible.
In the method presented, however, temperature gradients cannot be avoided, in consequence of which the compensation accuracy is limited. Nevertheless the method makes possible the full automation of the compensation procedure. The unit price of this company's complete pressure transducers is $10 in lots of 10 000 units, so they are several tens of times cheaper than the transducers of all other competing companies.
3.7. Summary
The known temperature-compensation methods presented above may be characterized as follows: (a) none of the known methods makes complete compensation of the temperature errors possible. In almost all the methods only one compensation temperature is used, with the exception of the Honeywell method with three-point compensation, i.e. with two temperatures; (b) only one method, developed by Kulite, ensures unidirectional independence in setting the compensation conditions, since the values of the resistors , , (Fig. 4) adjusted at the compensation temperature do not affect the signal of the transducer at the reference temperature; (c) in each of the methods presented, the number of values of the compensating components necessary to compensate all the sensors
in a production lot is large. In all the designs in which the compensating components are connected in series with the strain gauges, great difficulties arise, either in making or in purchasing stable components with values of the order of a few ohms or fractions of an ohm, which always go together with the use of low-resistance gauges (e.g. 100 Ω); (d) the compensation procedure based on all the known methods, with the exception of the method developed by Kulite, is difficult and burdensome under production conditions; (e) the conceptually most interesting method, that of National Semiconductor, requires repeating the temperature cycles many times, which, because of the time required, is unfeasible if another technology of manufacturing the transducer is used, and also because of the temperature gradients that occur if the requirements as to the compensation accuracy are raised.10
In view of the above, in the author's opinion it appears expedient to develop a new method of compensation of the effect of temperature in semiconductor pressure transducers, one which eliminates the drawbacks of the methods known and used hitherto.
Translator's notes
- the symbol denotes the forward voltage in this section only; from Section 4 onward is the transducer output at the lower range value. Both uses are kept as printed. ↩
- original caption reads "Statham, USA 71" with the reference brackets not drawn in; evidently reference [71]. In panel (a) the lower-left bridge arm is lettered "R5" as printed; evidently , as rendered in the label list. ↩
- original reads "skompensowaną zależnością" ("a compensated dependence"); evidently "skomplikowaną" ("complicated"), as in the wording used for the ITT method below. ↩
- , are the outputs labelled OUT1, OUT2 in Fig. 6 ("WY" = Polish "wyjście", output); the printed symbols are kept in the text. ↩
- the figures label the currents J; the text writes them , , . Both are kept as printed. ↩
- the thesis spells the company "Balley"; this is evidently Bailey (Bailey Meter Co.), the assignee of reference [48]. Corrected here and in the caption of Fig. 11. ↩
- original reads "...", " i ", " i ", " i "; the subscript "s" (sensor) is typed as "5", and "13" is a mis-strike for "1s". Rendered according to the figure labels to . ↩
- original reads " i " and, in the next paragraph, " i "; as these are described as piezoresistors, they are evidently the diffused resistors , and , of Fig. 12 (the same "s"/"5" confusion as on the preceding page). Kept as printed, since is also the label of a separate compensation resistor in Fig. 12. ↩
- the thesis writes "National Semiconductors"; the company is National Semiconductor Corp. Corrected here, in the caption of Fig. 13 and in Section 3.7. ↩
- in (a) the original reads "stosuje się tylko temperaturę kompensacji" ("only compensation temperature is used"), the numeral being omitted; evidently "only one". In (b) the original cites "rys. 4"; the Kulite circuit with the resistors , , is Fig. 6. ↩